| Filename | Latest commit message | Latest commit date |
|---|---|---|
| STL | ||
| CHAPTERS.md | ||
| INSTRUCTION-GUIDE.md | ||
| LINKS.md | ||
| PARTS-BOM.md | ||
| README.md | ||
| STL-FILES.md | ||

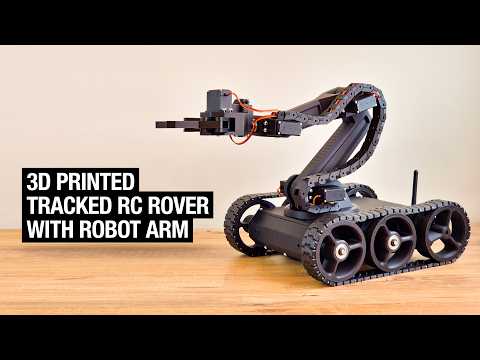
3D Printed Tracked Rover with Robot Arm
Documentation and reference repo for the YouTube project "3D Printed Tracked Rover with Robot Arm" by Emre Kalem (@emrekalemtech).
Video Info
| Field | Value |
|---|---|
| Title | 3D Printed Tracked Rover with Robot Arm |
| Channel | Emre Kalem (@emrekalemtech) |
| URL | https://www.youtube.com/watch?v=_5KeGOTaCFo |
| Published | 2026-08-02 |
| Duration | 25:31 |
| Views (at time of capture) | ~129,700 |
| Topics | rc rover, tracked rover, 3d printed rover, arduino, esp32, robot, jlcpcb |
Project Overview
A fully 3D-printable tracked RC rover with an integrated 6-DOF robotic arm and a custom controller built as a carrying case (the controller stows inside the case the rover travels in). It is presented as a practical, educational build for 3D printing and hobby-electronics enthusiasts.
Key subsystems:
- Drive train — two 37 mm 500 RPM DC motors with printed tracks, driven by an L298N motor driver
- Robot arm — 6 degrees of freedom via seven MG996R all-metal-gear servos, plus a gripper and a printed cable chain
- Rover brain — Arduino Mega 2560, powered from a 3S Li-Po through an XL4016 300 W boost converter
- Radio link — EBYTE E01-ML01DP5 (nRF24L01P) 2.4 GHz modules on both rover and controller
- Controller — Waveshare ESP32-C6-DEV-KIT-N8-M with two joystick modules, two potentiometers, powered by a single 18650 through an MT3608 boost converter
- PCBs — custom boards ordered from JLCPCB (gerbers linked below), hand-soldered
Repository Contents
| File | Description |
|---|---|
README.md |
This file — project overview and video info |
LINKS.md |
Every link from the video page (models, code, gerbers, schematics, socials) |
STL-FILES.md |
Complete inventory of all 38 STL files with sizes + per-file download links |
PARTS-BOM.md |
Full bill of materials (electronic + mechanical parts) |
INSTRUCTION-GUIDE.md |
Step-by-step build guide following the video's assembly stages |
CHAPTERS.md |
Timestamped chapter index of the video |
Note: The video has transcripts/captions disabled, so this repo's guide is reconstructed from the video's on-page description, chapter list, and linked resources. The firmware/sketches are not hosted here — download them from the Google Drive link in
LINKS.md.
Quick Start
- Download the STLs, code, and gerbers from the links in
LINKS.md. - Print all parts (see the build guide for print-order tips).
- Buy the parts listed in
PARTS-BOM.md. - Follow
INSTRUCTION-GUIDE.mdstage by stage — it mirrors the video's chapters so you can always jump back to the matching footage.
Credit
All design work, video, models, and code belong to Emre Kalem. This repo is an unaffiliated documentation/reference mirror of the project's public page info.